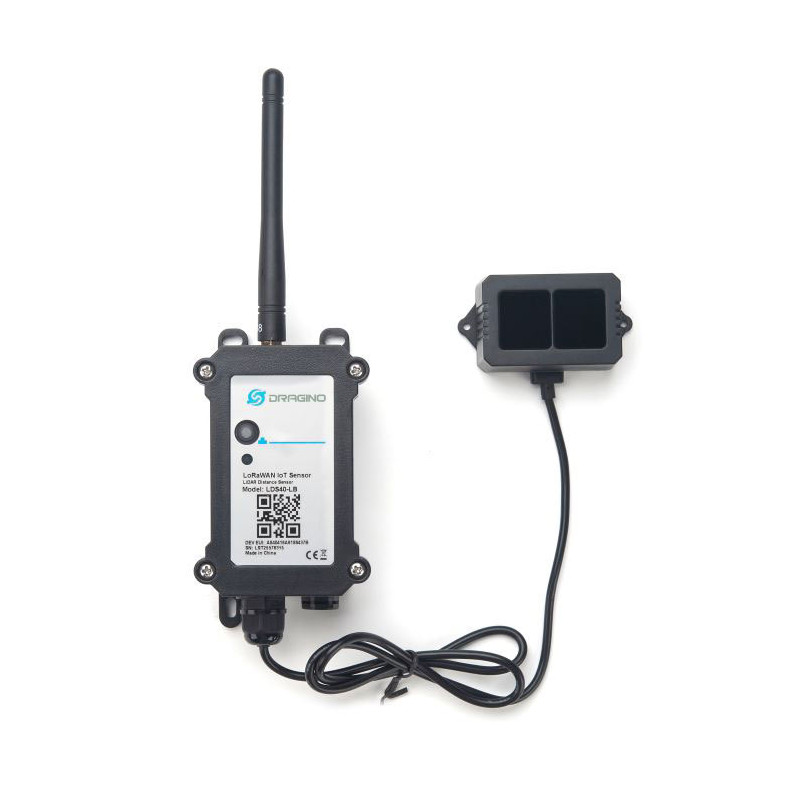
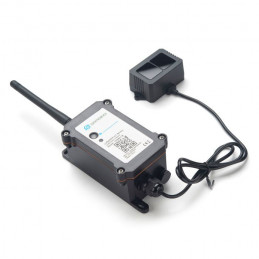
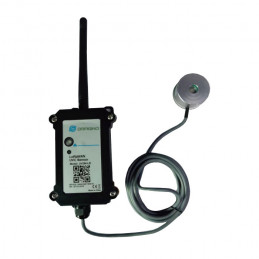
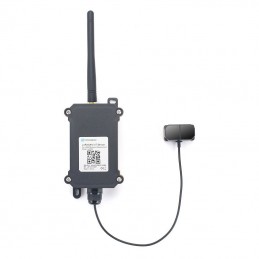
The LDS40-LB is Powered by a solar panel + li-on battery with a LiDAR ToF (Time of Flight) Distance Sensor for the Internet of Things solution. It is capable of measuring the distance to objects as close as 0m to 40m. The LiDAR probe uses laser induction technology for distance measurement.
The LDS40-LB can be applied to scenarios such as horizontal distance measurement, parking management system, object proximity and presence detection, intelligent trash can management system, robot obstacle avoidance, automatic control, sewer, etc.
It detects the distance between the measured object and the sensor and uploads the value wirelessly to the LoRaWAN IoT Server.
The LoRa wireless technology used in LDS40-LB allows the device to send data and reach extremely long ranges at low data rates. It provides ultra-long-range spread spectrum communication and high interference immunity while minimizing current consumption.
LDS40-LB supports BLE configuration and wireless OTA update makes users easy to use.
LDS40-LB is powered by an 8500mAh Li-SOCI2 battery, it is designed for long-term use up to 5 years.
Each LDS40-LB is pre-loaded with a set of unique keys for LoRaWAN registrations, register these keys to the local LoRaWAN server and it will auto-connect after powering on.
Features:
LoRaWAN 1.0.3 Class A
Bands: CN470/EU433/KR920/US915/EU868/AS923/AU915/IN865
Ultra-low power consumption
Laser technology for distance detection
Measure Distance: 0.1m~40m @ 90% Reflectivity
FOV : 3°
Monitor Battery Level
Support Bluetooth v5.1 and LoRaWAN remote configure
Support wireless OTA update firmware
AT Commands to change parameters
Downlink to change configure
8500mAh Li/SOCl2 Battery
Specification:
Common DC Characteristics:
Operating Temperature: -40 ~ 85°C
Probe Specification:
Storage temperature:-30°C~80°C
Operating temperature: -20°C~60°C
Measure Distance:
0.1m ~ 40m @ 90% Reflectivity
0.1m ~ 13.5m @ 10% Reflectivity
Distance resolution: 1cm
Ambient light immunity: 100klux
Enclosure rating: IP65
Light source: VCSEL
Central wavelength: 850nm
FOV : 3°
Material of enclosure: ABS+PC
Wire length: 75cm
LoRa Spec:
Frequency Range, Band 1 (HF): 862 ~ 1020 Mhz
Max +22 dBm constant RF output vs.
RX sensitivity: down to -139 dBm.
Excellent blocking immunity
Battery:
8500mAh Li/SOCl2 Battery
Capacity: 8500mAh
Self-Discharge: <1% / Year @ 25°C
Max continuous current: 130mA
Max boost current: 2A, 1 second
Power Consumption:
Sleep Mode: 5uA @ 3.3v
LoRa Transmit Mode: 125mA @ 20dBm, 82mA @ 14dBm
Applications:
Horizontal distance measurement
Parking management system
Object proximity and presence detection
Intelligent trash can management system
Robot obstacle avoidance
Automatic control
Sewer
Order Info
Part Number: LDS40-LS-XXX
XXX: the default frequency band
EU433: Default frequency band EU433
CN470: Default frequency band CN470
EU868: Default frequency band EU868
IN865: Default frequency band IN865
KR920: Default frequency band KR920
AS923: Default frequency band AS923
AU915: Default frequency band AU915
US915: Default frequency band US915
Package Includes:
LDS40-LB LoRaWAN LiDAR Distance Sensor x 1
Dimensions and Weight:
Package Dimension:150*120*55mm
Weight: 220g
Useful Link:
User Manual
Datasheet
Firmware